Autonomous, Robotic and Control Laboratory
Specializes in autonomous systems, path planning, and advanced vehicle dynamics.
The ARC Laboratory is a premier research facility within Faculty of Manufacturing and Mechatronic Engineering Technology (FTKPM), Universiti Malaysia Pahang Al-Sultan Abdullah (UMPSA) dedicated to advancing the frontiers of robotics, autonomous navigation, and intelligent control systems. We focus on bridging the gap between theoretical algorithms and real-world robotic deployments.
Explore Our JourneyDiscover our flagship initiatives and cutting-edge projects shaping the future of autonomous systems, edge computing, and robotic technologies.
Lead Researcher
Investigating AI-driven navigation and secure edge computing for surveillance and reconnaissance robots. A multi-institutional collaboration pushing the boundaries of autonomous systems in complex environments.
Core Member
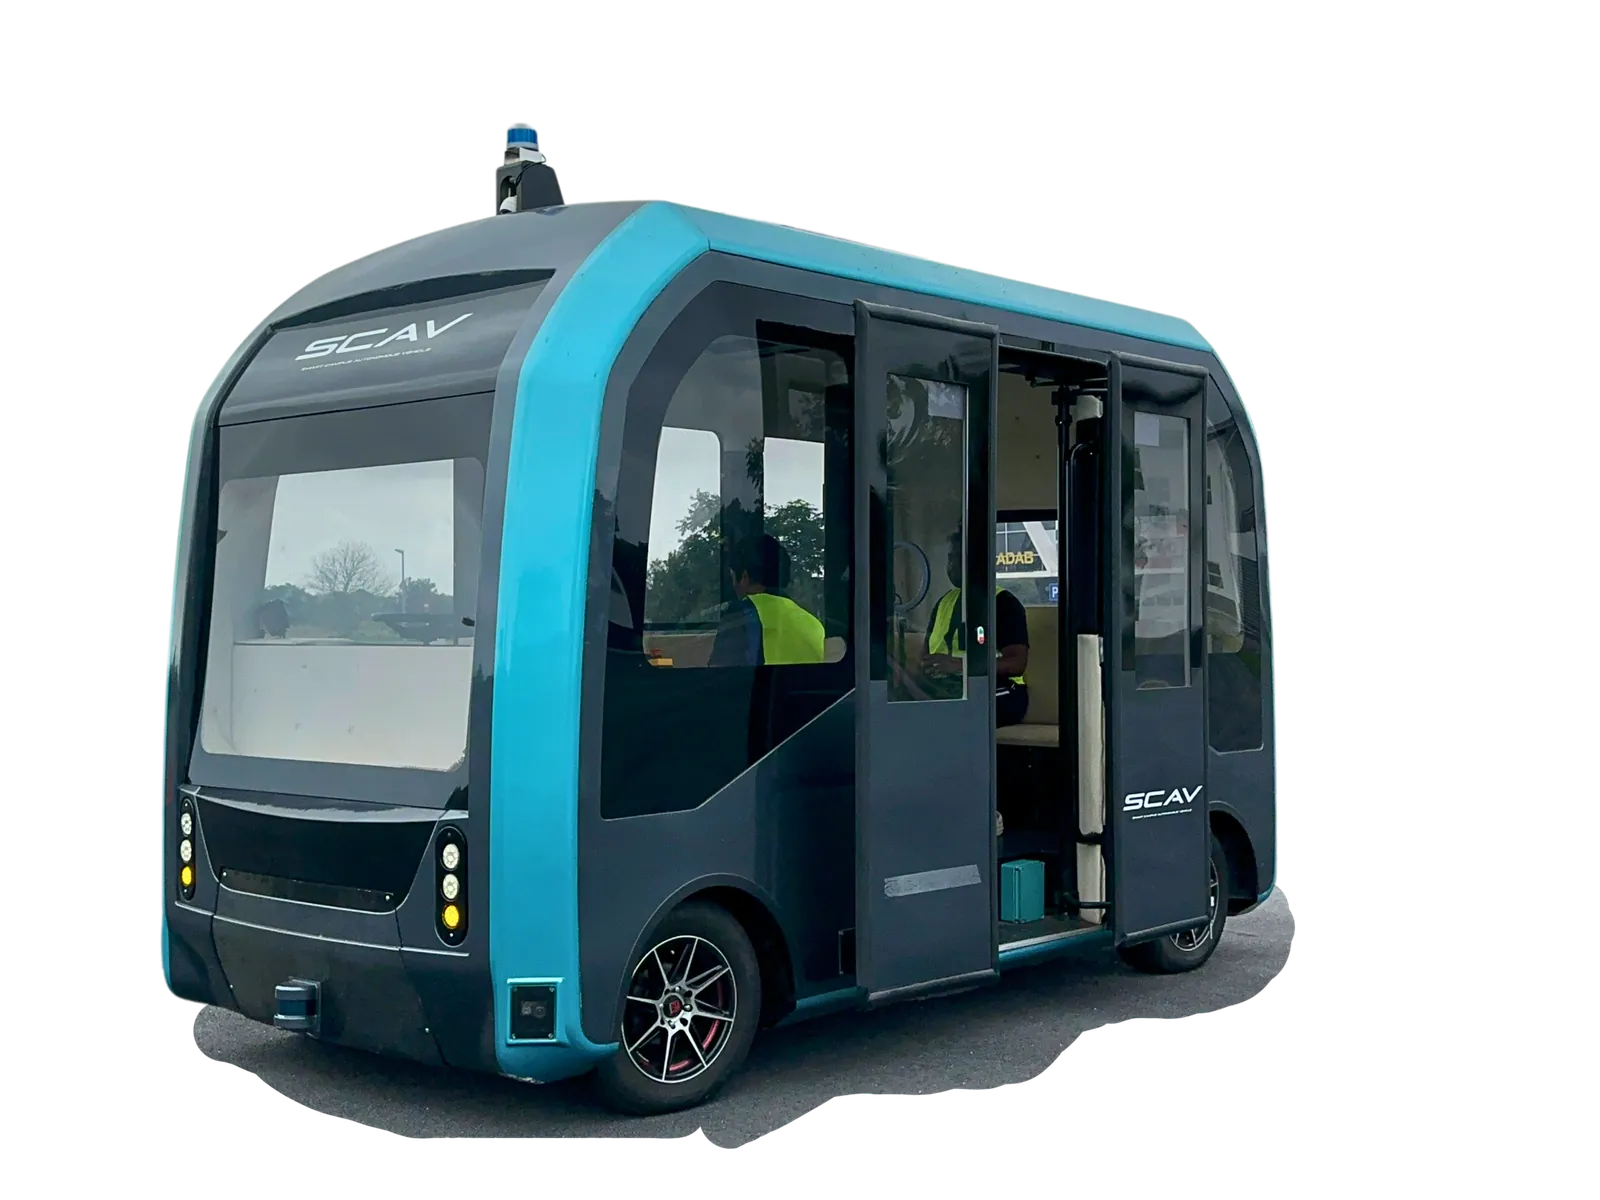
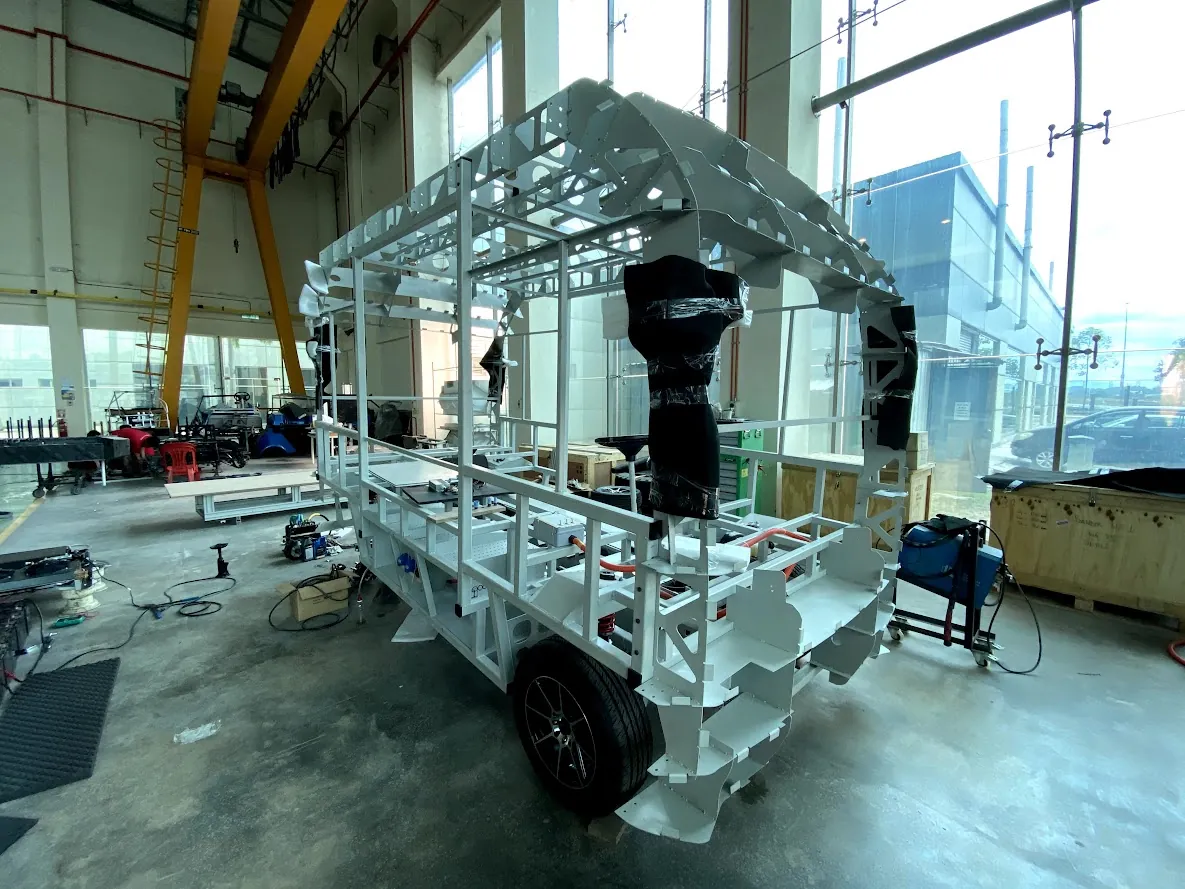
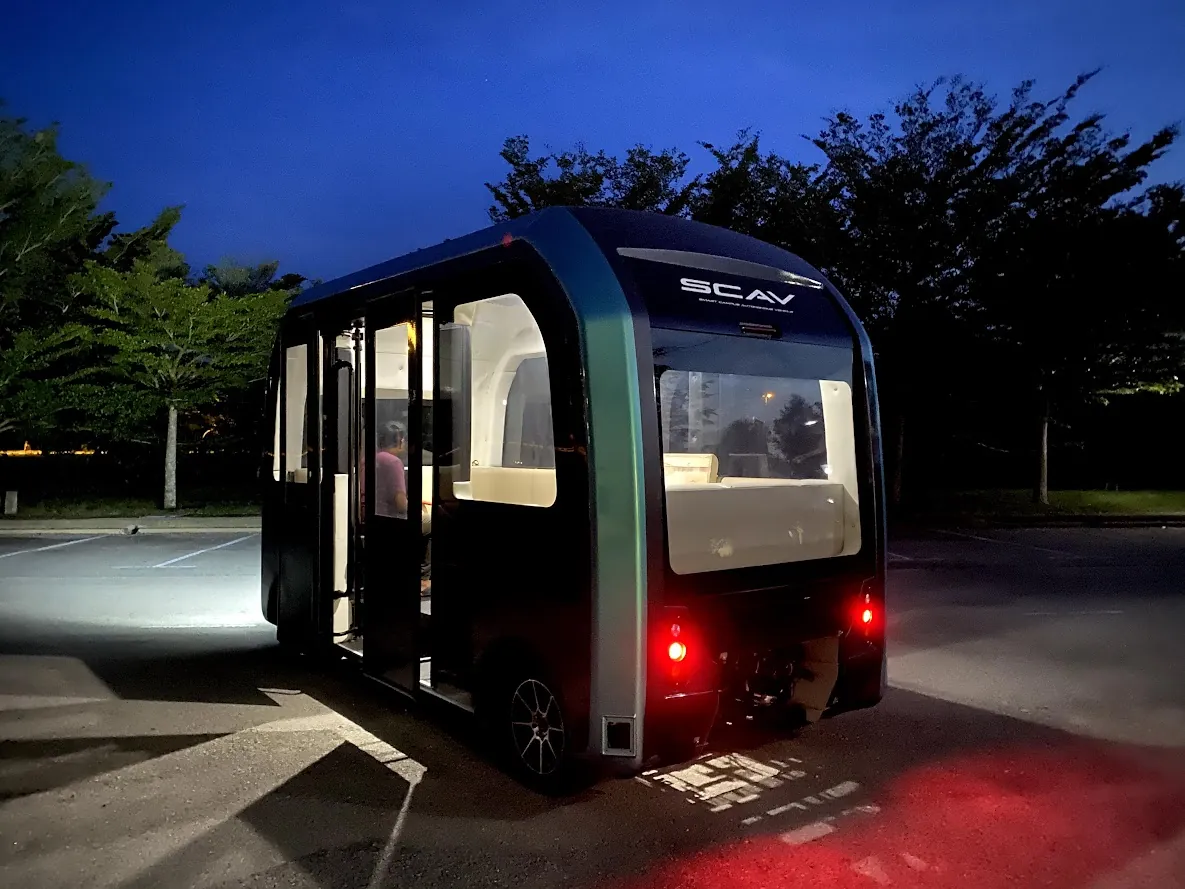
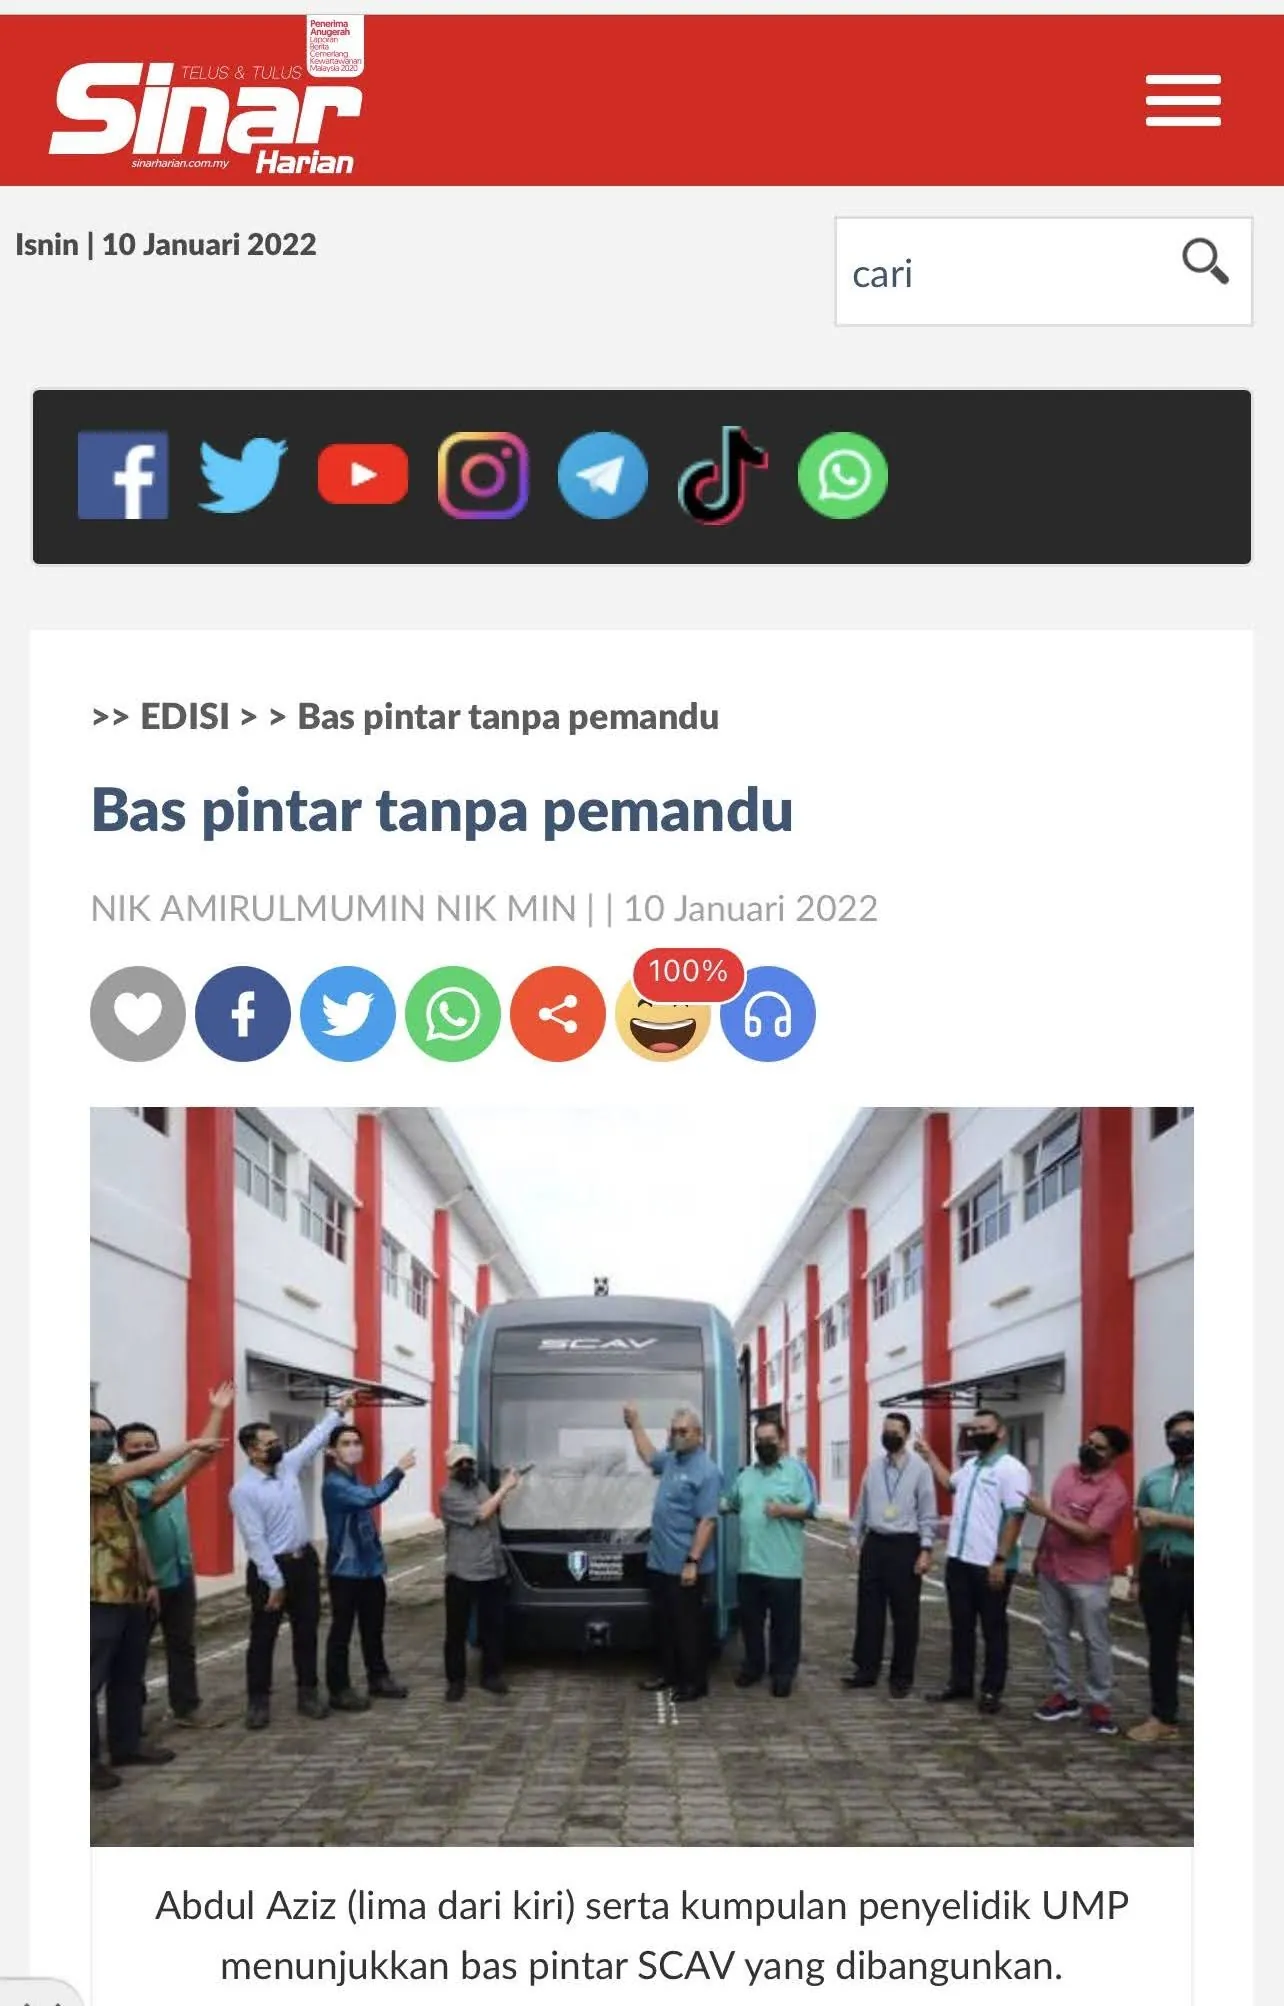
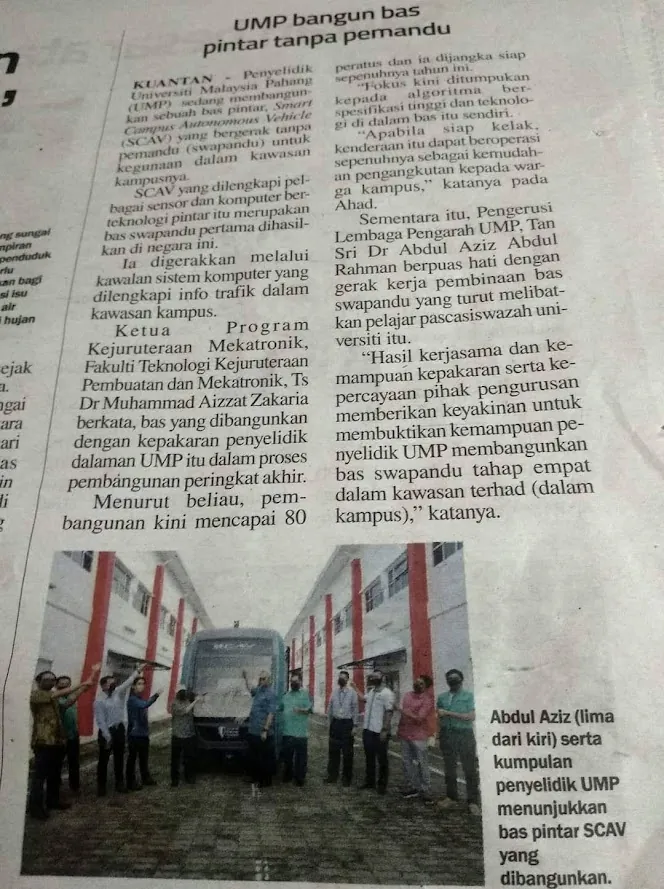
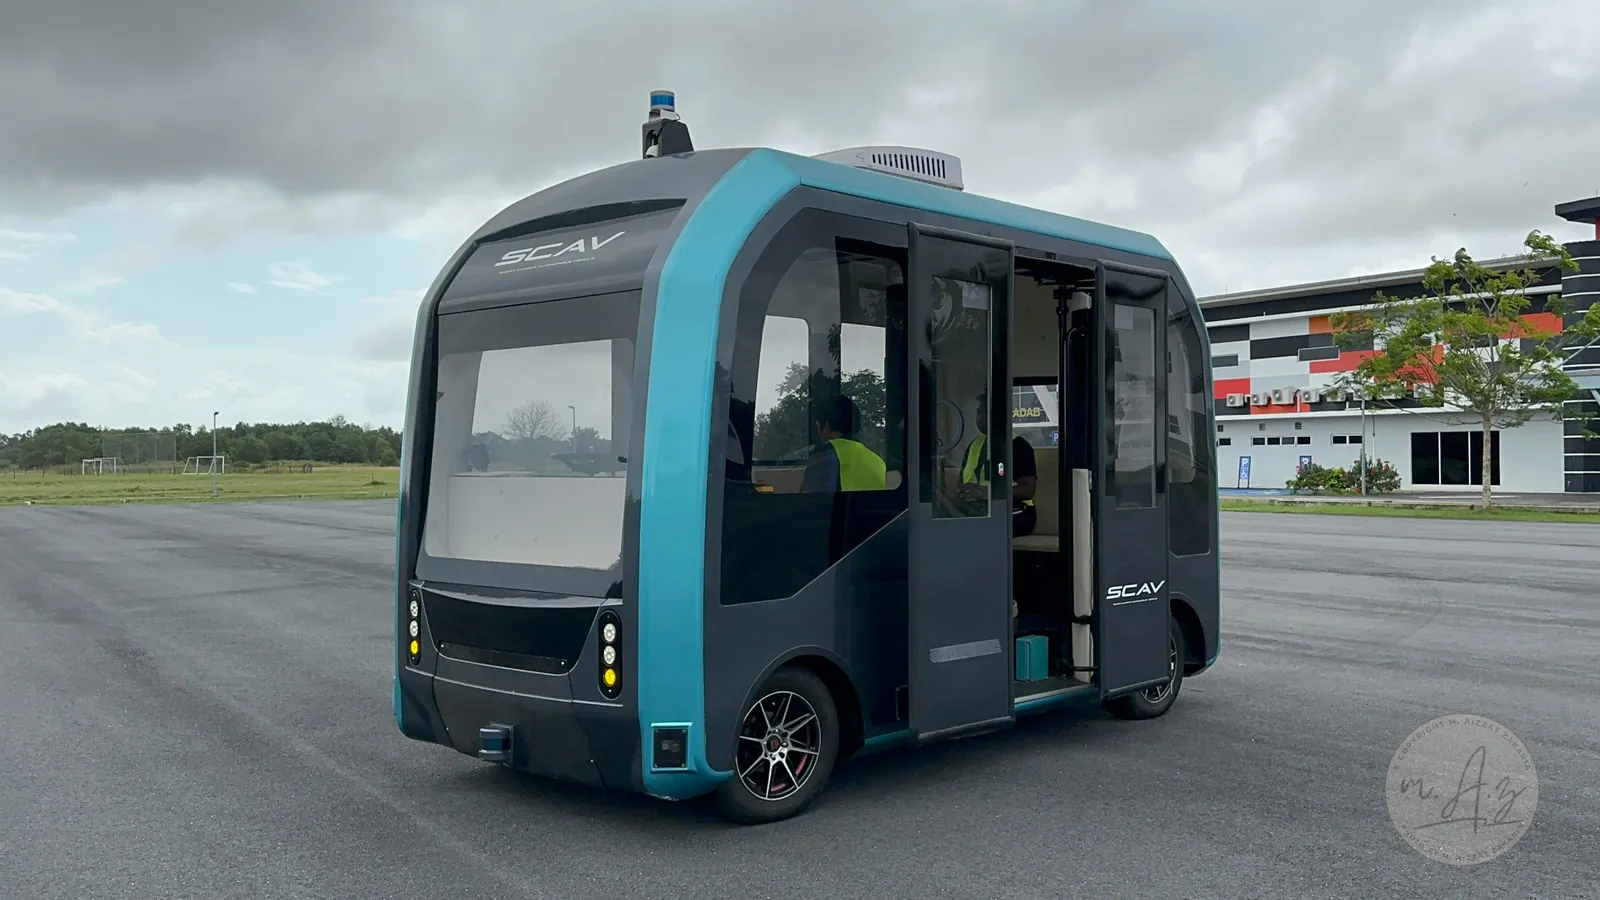
A pioneering autonomous shuttle developed locally by UMPSA researchers. Focuses on AV system architecture, SLAM technology development, perception algorithms, and ROS architecture.
Project Leader
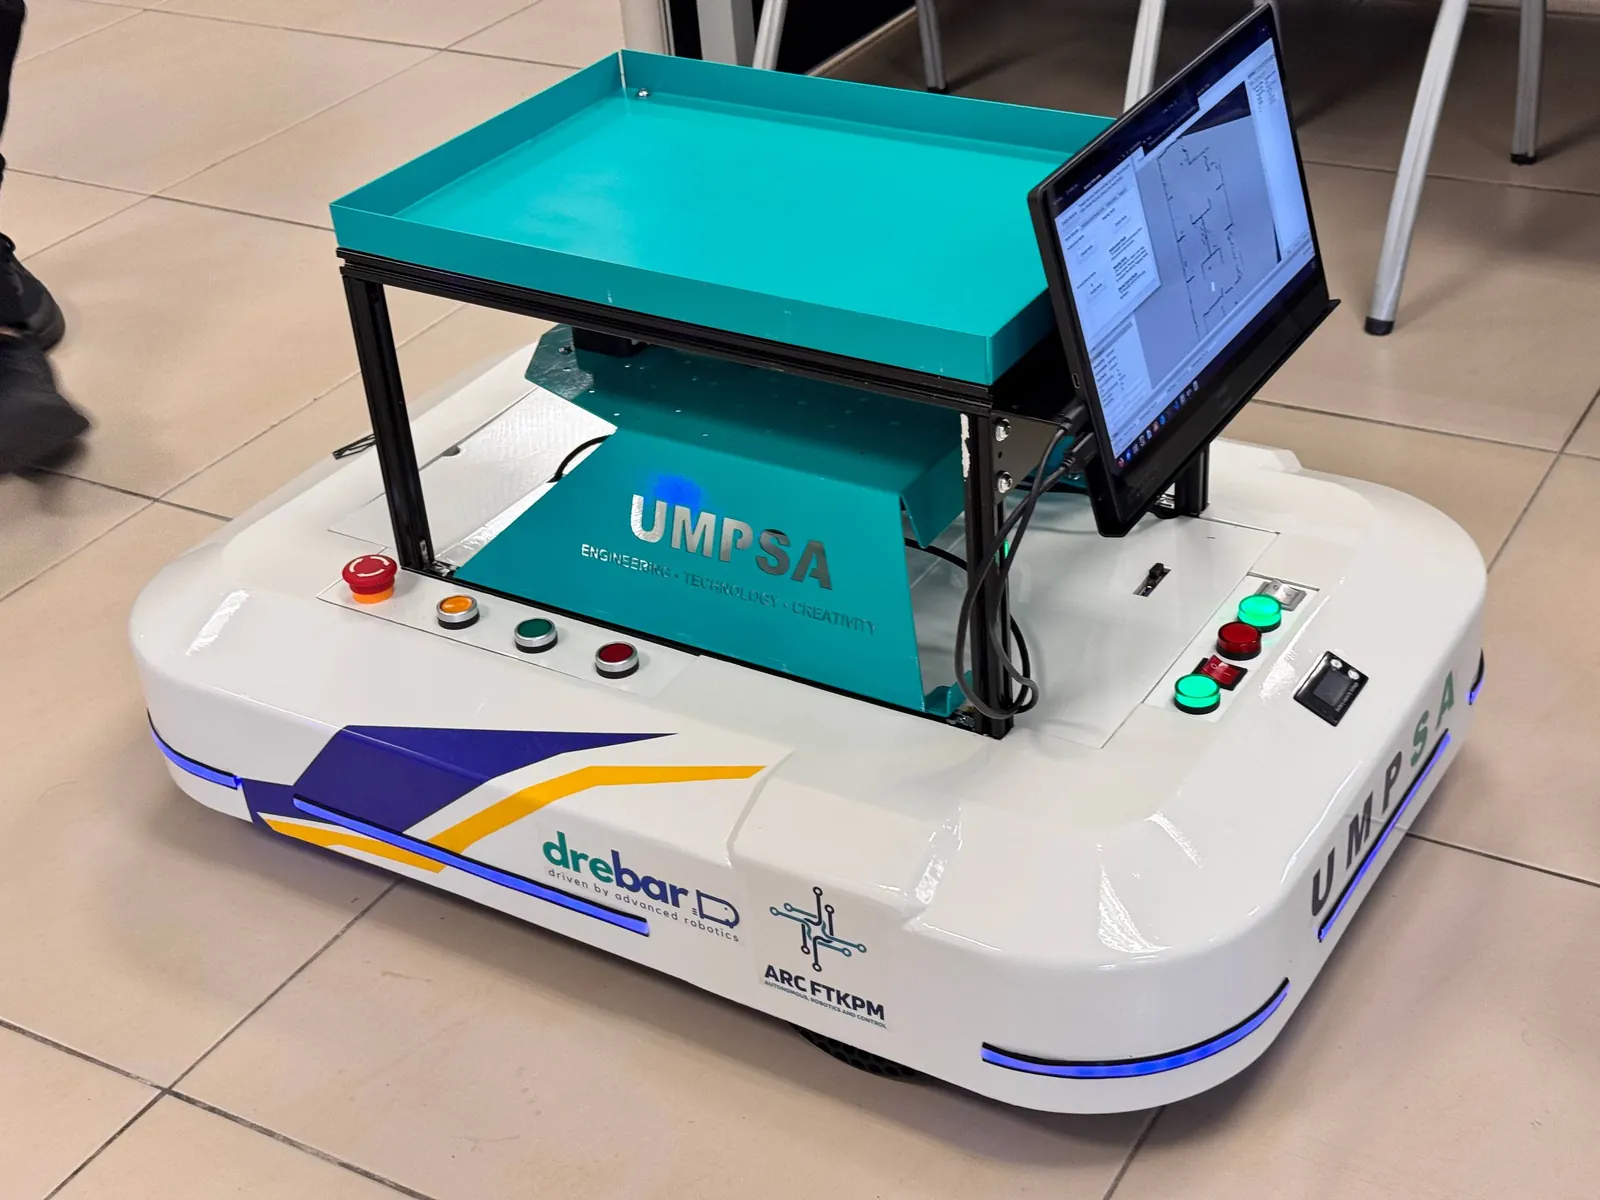
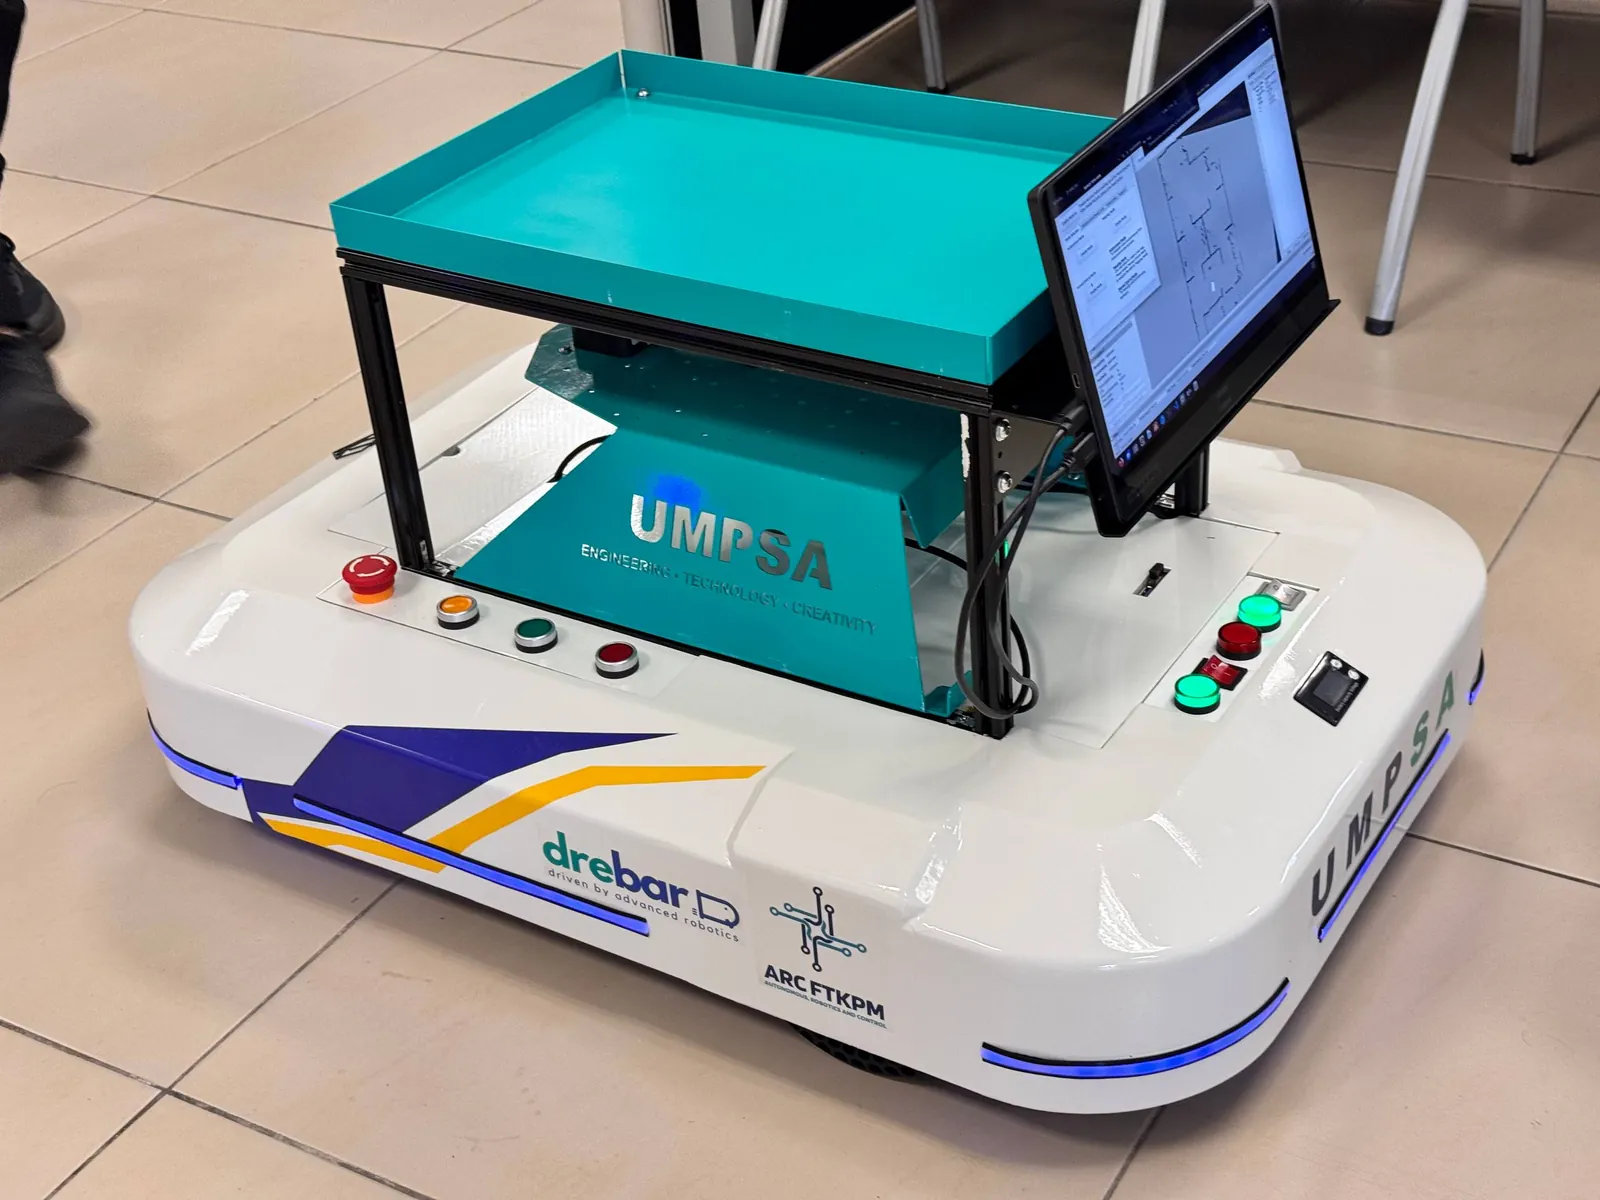
Development of an autonomous delivery robot utilizing the DREBAR firmware ("Made in UMPSA"). Focuses on creating intelligent mobile robots for research and educational purposes.
Fundamental Research
Research into vehicle dynamics, including Active Stability Control and Predictive Stability Models. Aims to improve passenger comfort and safety in autonomous driving scenarios.
Experience our autonomous platforms and robotic solutions operating in real-world scenarios through these live demonstrations.
Trace the evolution of our laboratory from its inception, highlighting key milestones, technological breakthroughs, and significant deployments.
Initial conceptualization and development phase of the autonomous vehicle framework within the campus.
Development of Autonomous Forklift for the Teaching Factory, integrating industrial automation.
Creation of a specialized autonomous robot designed for last-mile parcel delivery services.
Development of the Autonomous Mobile Robot (DREBAR-AMR) for versatile mobility applications.
Exploration of Autonomous Vehicle applications across different sectors including national security and agriculture.
Our structured approach to advancing autonomous vehicle technologies, moving from foundational development to commercial deployment.
Meet the dedicated team of experts and visionaries driving innovation in autonomous systems and advanced control engineering.
Empowering the next generation of engineers with industry-relevant skills and specialized consultation services.
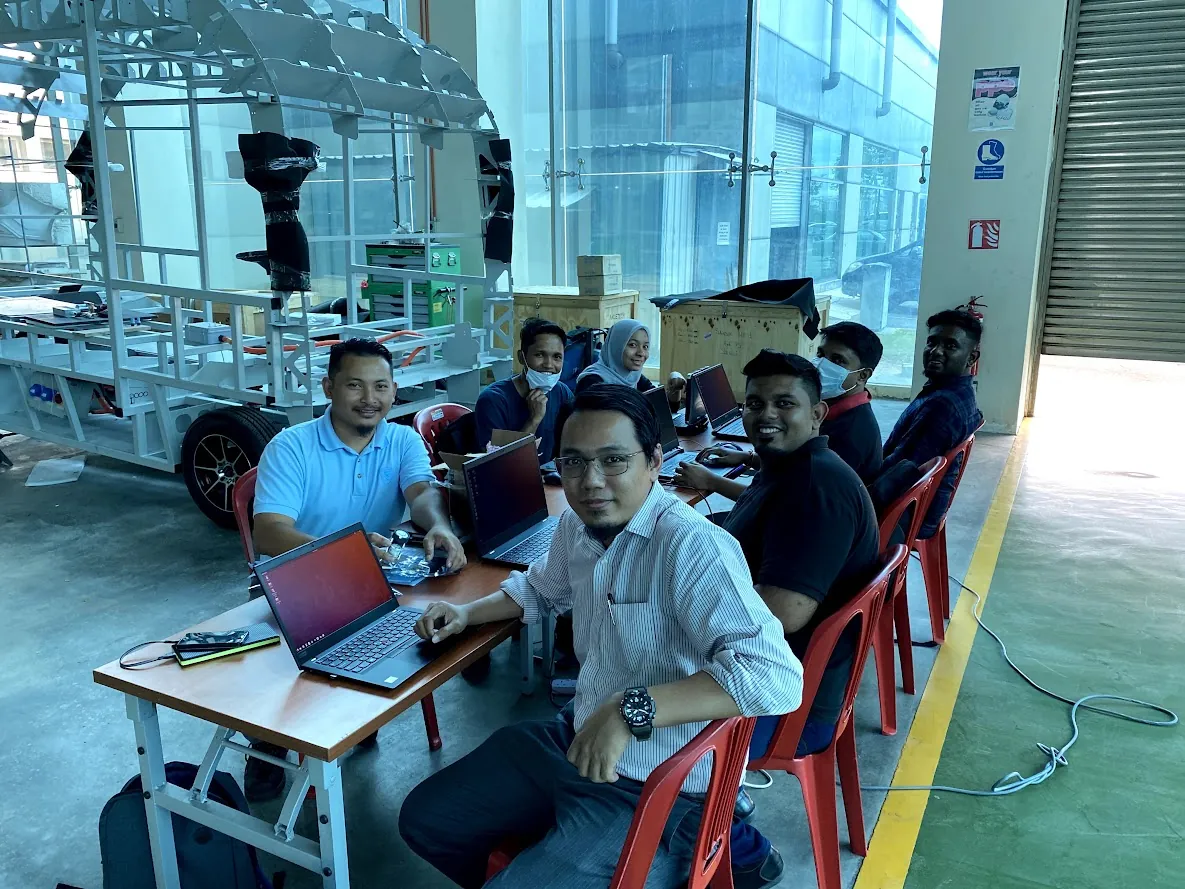
Example of our hands-on autonomous training sessions, equipping participants with real-world skills in robotic systems.
ROS1 & ROS2
3D Printing & Prototyping
with Agentic AI
Industrial & Mobile Robots
System Architecture & Design
A showcase of our registered patents, trademarks, copyrights, and industrial designs resulting from continuous research and innovation.
PI2026002275
2021003841
TM2025041899
TM2025041905
TM2025041906
LY2022C03925
25-E1554-0101
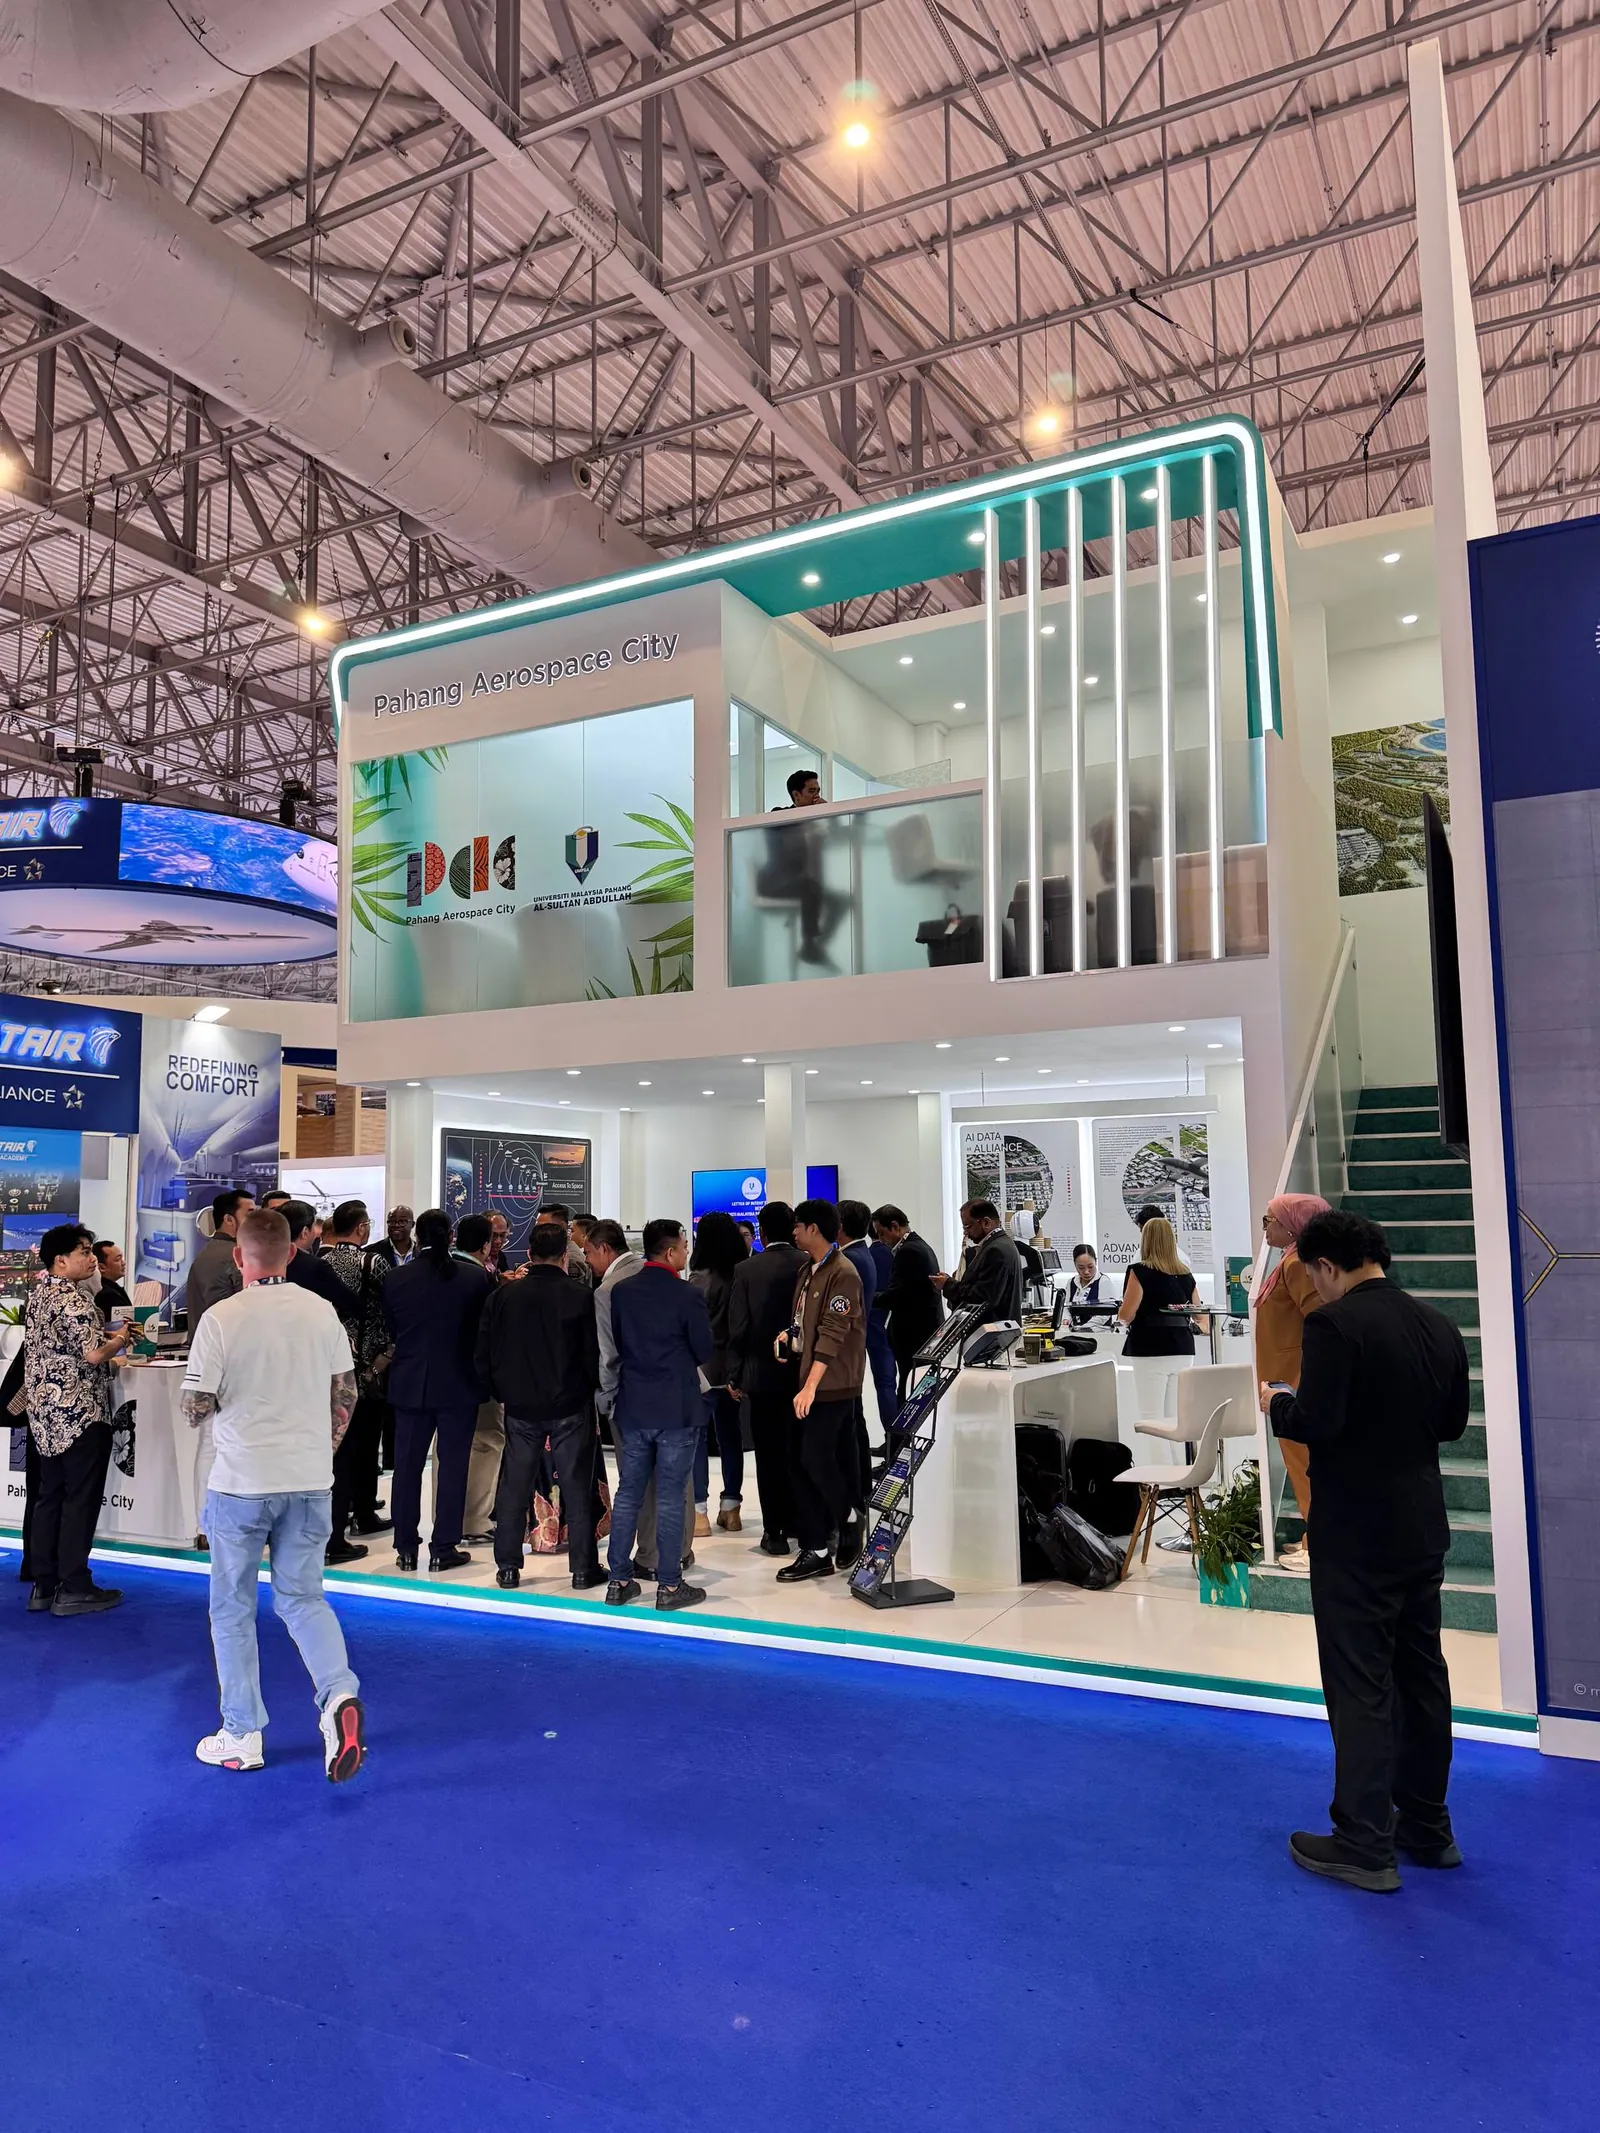
ARC FTKPM represented Universiti Malaysia Pahang Al-Sultan Abdullah alongside PIX Moving at Paris Expo · Porte de Versailles (Hall 7.1 · Stand C01) from 12–18 October 2026. On 15 October, the three partners exchanged a Memorandum of Agreement for the pilot deployment of RoboBus in Malaysia, witnessed by the Ambassador of Malaysia to France.
ARC FTKPM is privileged to officially represent UMPSA at Mondial de l’Auto (Paris Motor Show 2026), one of the world's most prestigious automotive exhibitions. Sharing an official stand with global autonomous mobility innovator PIX Moving, our research team will showcase Malaysian autonomous vehicle architectures, deep-tech multi-sensor fusion, localized sensor tuning, custom DREBAR multi-robot coordination firmware, and intelligent campus mobility to international automotive industry leaders.
Following successful representation at Dubai Airshow, ARC FTKPM advances UMPSA's international research presence to Paris Expo Porte de Versailles.
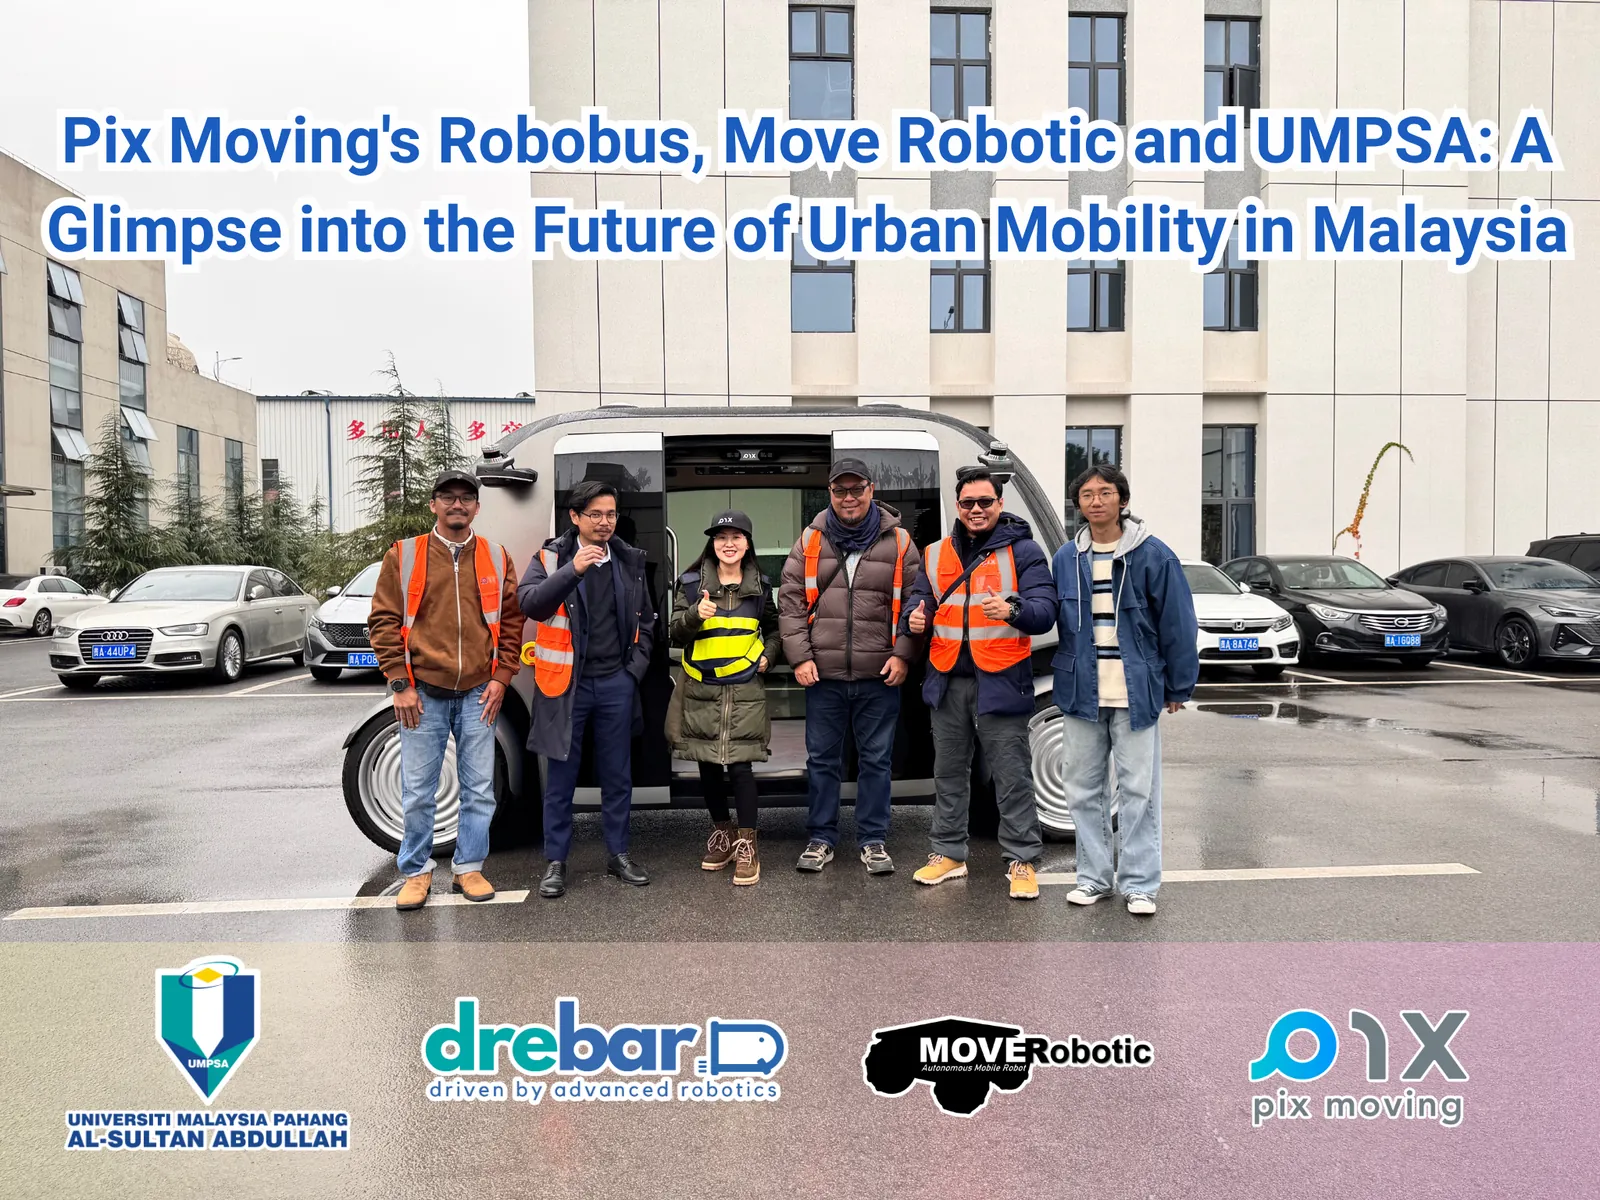
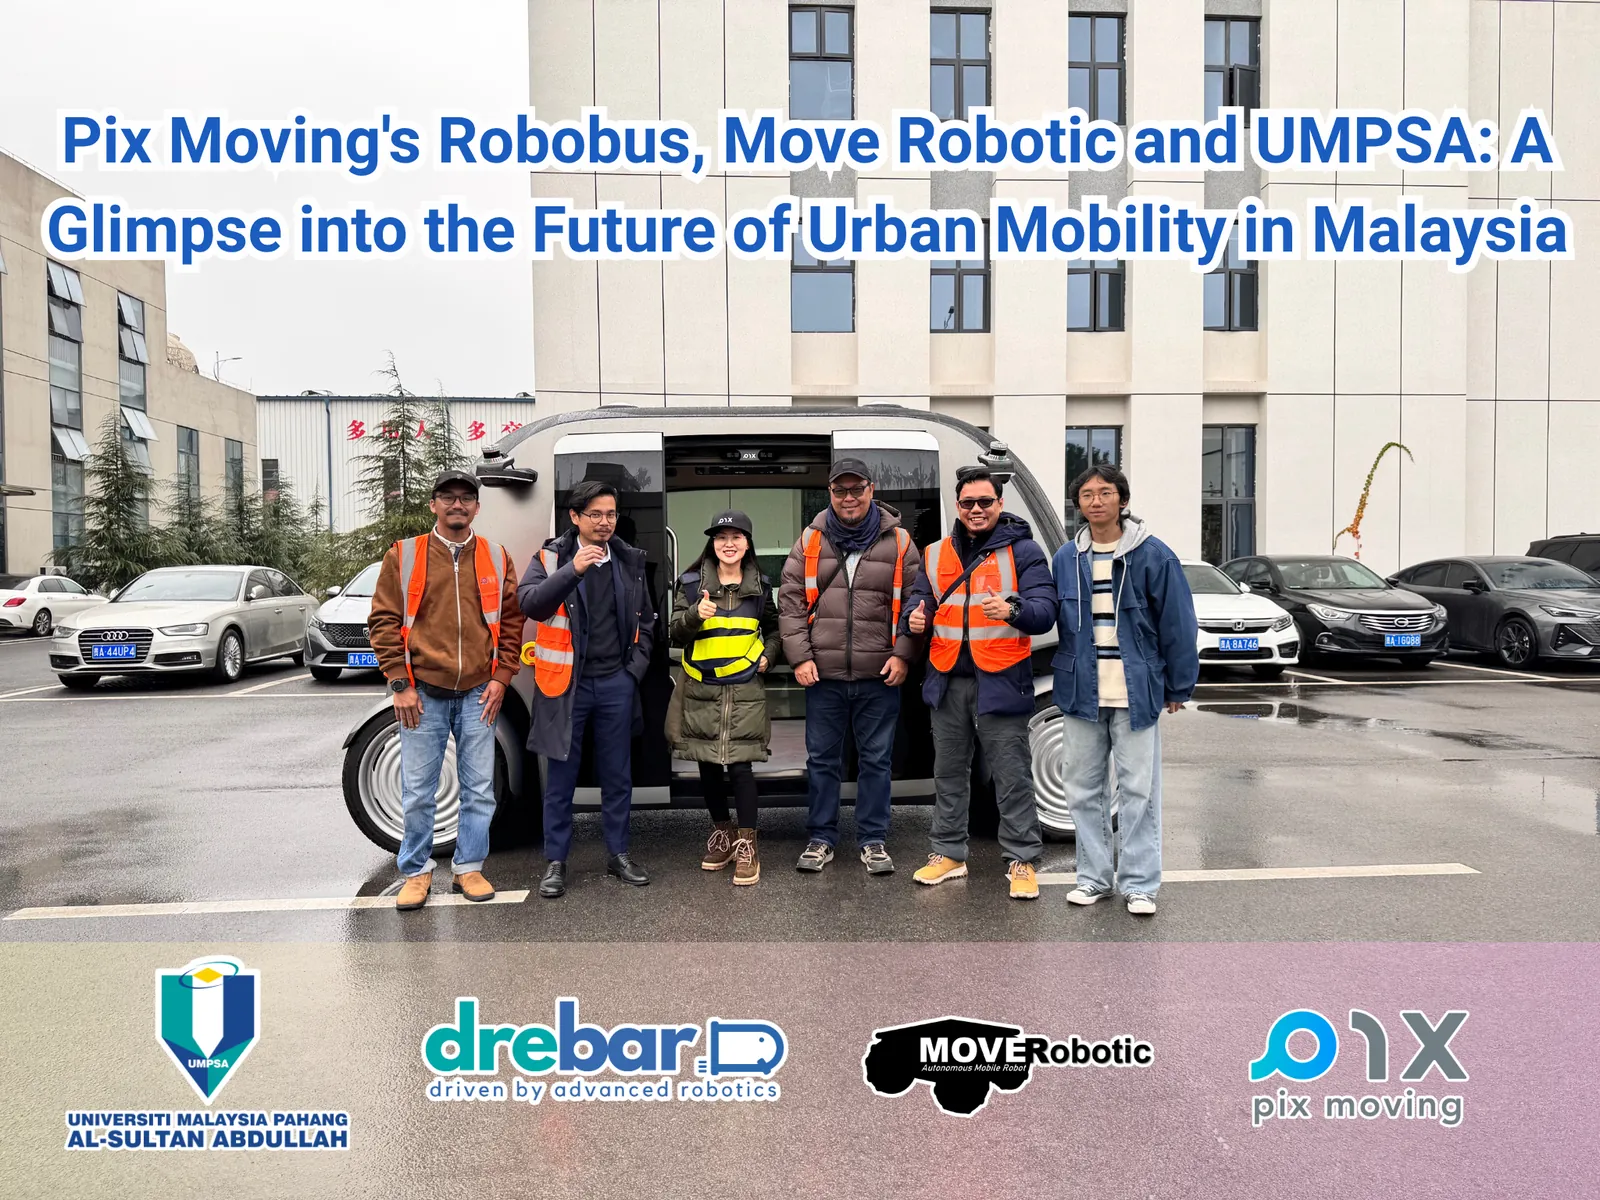
A flagship highlight of the joint collaboration between PIX Moving and ARC FTKPM is the upcoming deployment of the Robobus in Malaysia. Designed as an autonomous mobile space built around passenger comfort rather than a driver's seat, the Robobus delivers zero-emission, programmable micro-mobility for university campuses, smart townships, and urban public transit.
UMPSA (ARC FTKPM) leads the deep-tech R&D pipeline: advancing autonomous vehicle algorithms, multi-sensor fusion architectures, localized sensor tuning, tropical monsoon data collection, custom DREBAR firmware for multi-robot coordination and tracking, campus testbed deployment, and specialized expert R&D training for engineers and clients.
ARC FTKPM and PIX Moving partnership bringing smart autonomous shuttles to Malaysian universities and townships.
Official Robobus autonomous testbed and deployment collaboration video in Malaysia.
DREBAR is ARC FTKPM's flagship proprietary robotics firmware—proudly developed at UMPSA ("Made in UMPSA") and officially registered under multiple trademark classes. At the Paris Motor Show 2026, DREBAR's R&D steps onto the global automotive and industrial robotics stage.
Engineered to bridge the gap between low-level motor actuation and high-level ROS 2 navigation, DREBAR empowers autonomous mobile robots (AMRs), delivery units, and drive-by-wire vehicle platforms with deterministic, real-time control.
Demonstrating how Malaysian university research evolves into globally competitive autonomous vehicle firmware.
Discover recent research milestones, international showcases, national media features, grant awards, and field deployment breakthroughs from the ARC FTKPM Laboratory.
Interested in collaboration, research opportunities, or have any inquiries regarding the ARC FTKPM lab? We'd love to hear from you.
Lead of Technical Development
ismayuzri@umpsa.edu.my
Full engineering architecture, dimensions, autonomous stack, and Malaysia deployment specs.
UMPSA delivers customized sensor fusion algorithms, localized tropical precipitation de-noising, proprietary DREBAR multi-robot coordination firmware, and certified R&D training for Malaysian engineering teams.
| Vehicle Dimensions | 3,810 mm (L) × 1,960 mm (W) × 2,200 mm (H) |
|---|---|
| Passenger Capacity | Up to 6 Passengers (Configurable Living Space) |
| Operational Speed | 20 – 35 km/h (Software geofence-governed) |
| Battery & Range | 31.94 kWh Lithium Iron Phosphate · 70 – 120 km range |
| Chassis Architecture | PIX Ultra-Skateboard Chassis (Bi-directional drive, 4-wheel independent steering) |
| Turning Radius | Zero-radius crab & symmetric steering capability |
| Perception Sensors | 3D Solid-State LiDARs, Automotive mmWave Radars, 360° HDR Vision, Dual RTK-GNSS/IMU |
| Autonomous Level | Level 4 (L4) Geofenced Micro-Transit with redundant safety watchdogs |
| Control Protocol | Drive-by-Wire via high-frequency CAN Bus 2.0B & ROS 2 / Autoware integration |
| Deployment Partner | Move Robotic Sdn Bhd (Nationwide deployment, SLA maintenance, services & business models) |
Equatorial monsoon rain filtering, lens spray mitigation, and glare compensation tuned by UMPSA.
Centralized telemetry tracking, sub-ms CAN bus actuation, and multi-robot coordination.